
Инкрементални енкодери
Incremental Encoders
10229 продукта · стр. 133/427
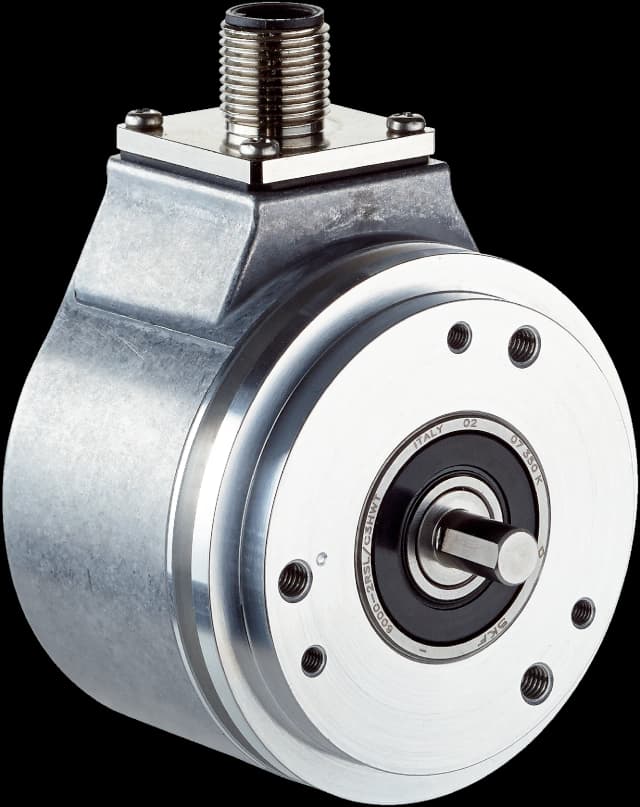
DBS60E-S1EC00010
Incremental encoders | DBS60 | DBS60E-S1EC00010 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 10 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EC00020
Incremental encoders | DBS60 | DBS60E-S1EC00020 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 20 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EC00050
Incremental encoders | DBS60 | DBS60E-S1EC00050 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 50 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EC00100
Incremental encoders | DBS60 | DBS60E-S1EC00100 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 100 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EC00360
Incremental encoders | DBS60 | DBS60E-S1EC00360 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 360 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EC00500
Incremental encoders | DBS60 | DBS60E-S1EC00500 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 500 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EC01000
Incremental encoders | DBS60 | DBS60E-S1EC01000 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 1,000 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EC01024
Incremental encoders | DBS60 | DBS60E-S1EC01024 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 1,024 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EC02000
Incremental encoders | DBS60 | DBS60E-S1EC02000 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 2,000 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EC03600
Incremental encoders | DBS60 | DBS60E-S1EC03600 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 3,600 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
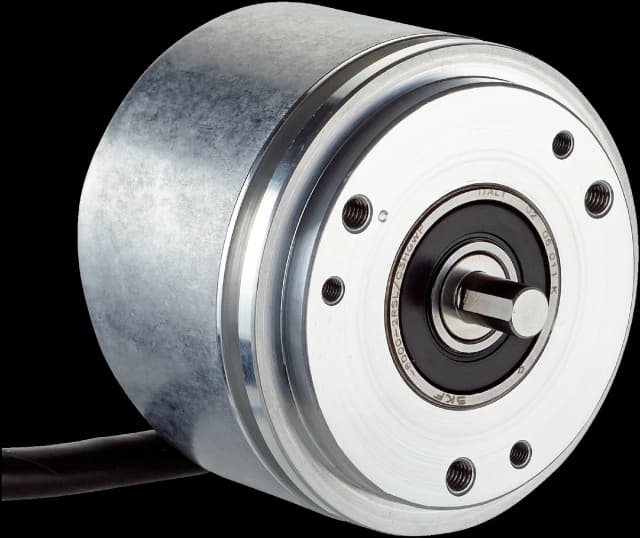
DBS60E-S1EK00010
Incremental encoders | DBS60 | DBS60E-S1EK00010 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 10 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EK00360
Incremental encoders | DBS60 | DBS60E-S1EK00360 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 360 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EK00500
Incremental encoders | DBS60 | DBS60E-S1EK00500 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 500 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EK01000
Incremental encoders | DBS60 | DBS60E-S1EK01000 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 1,000 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EK01024
Incremental encoders | DBS60 | DBS60E-S1EK01024 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 1,024 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EK02000
Incremental encoders | DBS60 | DBS60E-S1EK02000 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 2,000 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EK05000
Incremental encoders | DBS60 | DBS60E-S1EK05000 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 5,000 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EL01000
Incremental encoders | DBS60 | DBS60E-S1EL01000 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 3 m | Pulses per revolution: 1,000 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EM00360
Incremental encoders | DBS60 | DBS60E-S1EM00360 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 5 m | Pulses per revolution: 360 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EM05000
Incremental encoders | DBS60 | DBS60E-S1EM05000 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 5 m | Pulses per revolution: 5,000 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EN00360
Incremental encoders | DBS60 | DBS60E-S1EN00360 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 10 m | Pulses per revolution: 360 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EN01000
Incremental encoders | DBS60 | DBS60E-S1EN01000 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 10 m | Pulses per revolution: 1,000 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EN02500
Incremental encoders | DBS60 | DBS60E-S1EN02500 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 10 m | Pulses per revolution: 2,500 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4
DBS60E-S1EN05000
Incremental encoders | DBS60 | DBS60E-S1EN05000 | Mechanical design: Solid shaft Servo flange 6 mm x 10 mm (With flat) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, universal, 10 m | Pulses per revolution: 5,000 | Flange type / stator coupling: Flange with 3 x M3 and 3 x M4