
Инкрементални енкодери
Incremental Encoders
10229 продукта · стр. 130/427
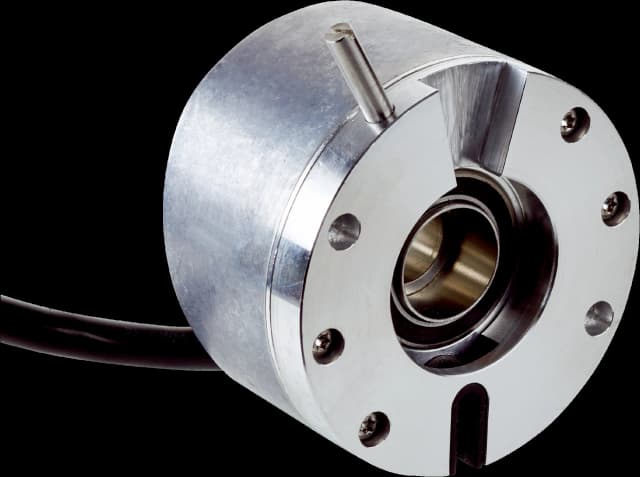
DBS60E-RJEQC1024
Incremental encoders | DBS60 | DBS60E-RJEQC1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, with male connector, M23, 12-pin, universal, 0.5 m | Pulses per revolution: 1,024 | Flange type / stator coupling: Axial and radial register pin mounting, for 4 mm register pin
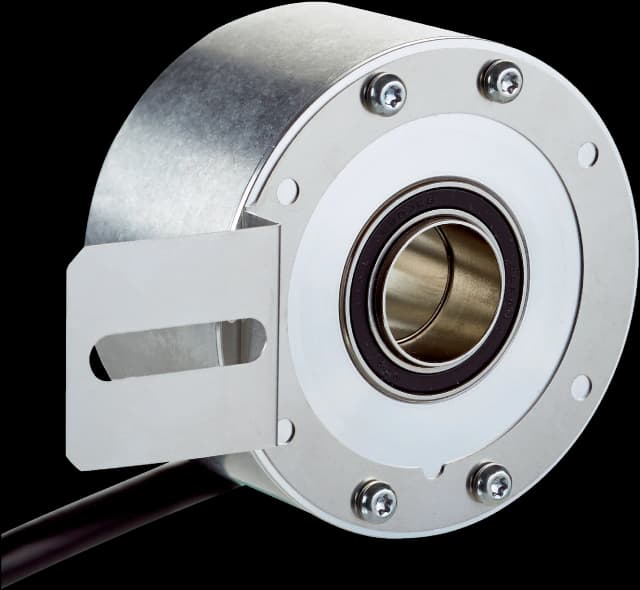
DBS60E-RJEQD1024
Incremental encoders | DBS60 | DBS60E-RJEQD1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 10 V ... 27 V, HTL, Push pull | Connection type: Cable, 8-wire, with male connector, M23, 12-pin, universal, 0.5 m | Pulses per revolution: 1,024 | Flange type / stator coupling: 1-sided stator coupling, slot, screw hole circle radius 31.5–48.5 mm
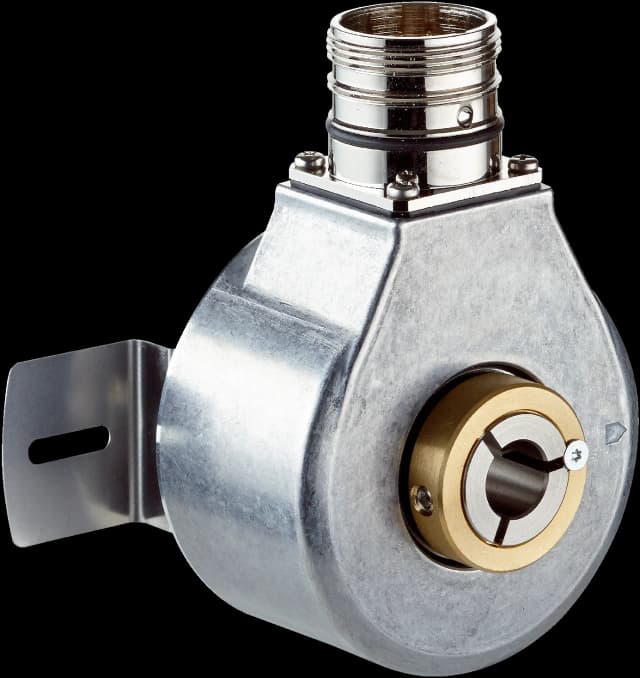
DBS60E-RJFA00100
Incremental encoders | DBS60 | DBS60E-RJFA00100 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Male connector, M23, 12-pin, radial | Pulses per revolution: 100 | Flange type / stator coupling: 2-sided stator coupling, slot, screw hole circle 63–83 mm
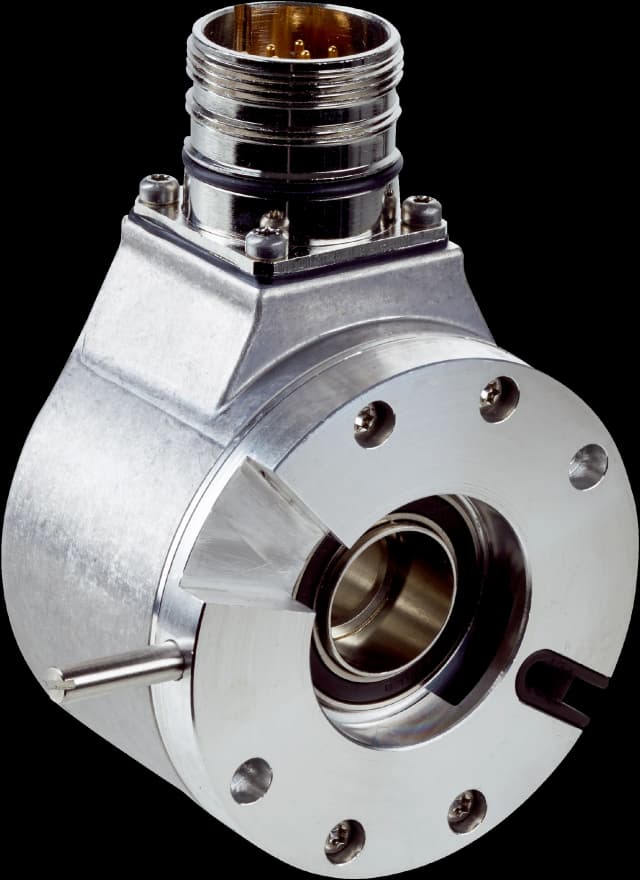
DBS60E-RJFAC1024
Incremental encoders | DBS60 | DBS60E-RJFAC1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Male connector, M23, 12-pin, radial | Pulses per revolution: 1,024 | Flange type / stator coupling: Axial and radial register pin mounting, for 4 mm register pin
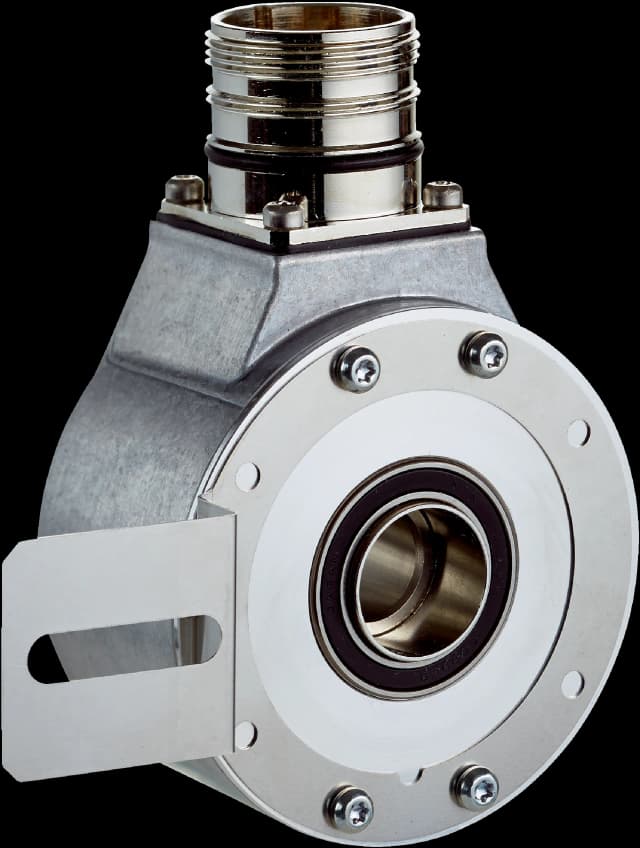
DBS60E-RJFAD1024
Incremental encoders | DBS60 | DBS60E-RJFAD1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Male connector, M23, 12-pin, radial | Pulses per revolution: 1,024 | Flange type / stator coupling: 1-sided stator coupling, slot, screw hole circle radius 31.5–48.5 mm
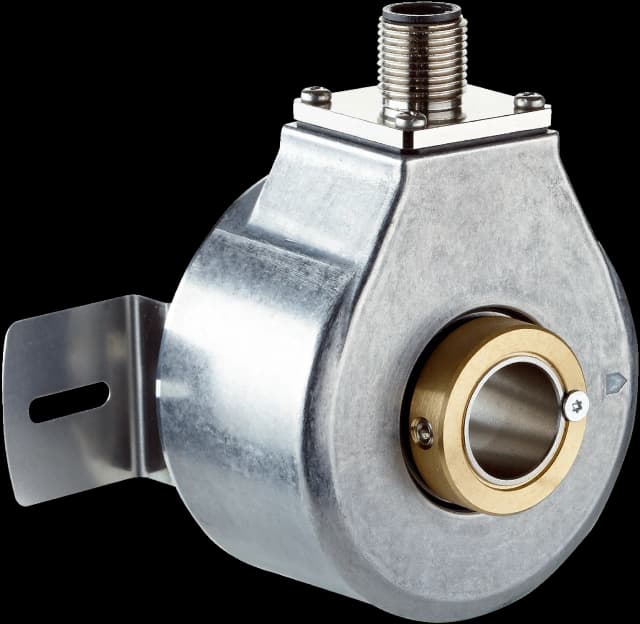
DBS60E-RJFC00100
Incremental encoders | DBS60 | DBS60E-RJFC00100 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 100 | Flange type / stator coupling: 2-sided stator coupling, slot, screw hole circle 63–83 mm
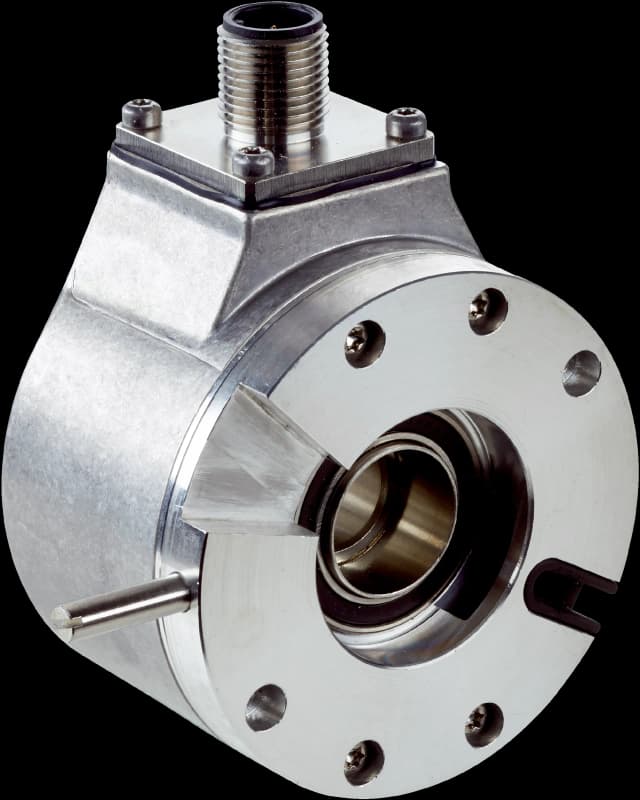
DBS60E-RJFCC1024
Incremental encoders | DBS60 | DBS60E-RJFCC1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 1,024 | Flange type / stator coupling: Axial and radial register pin mounting, for 4 mm register pin
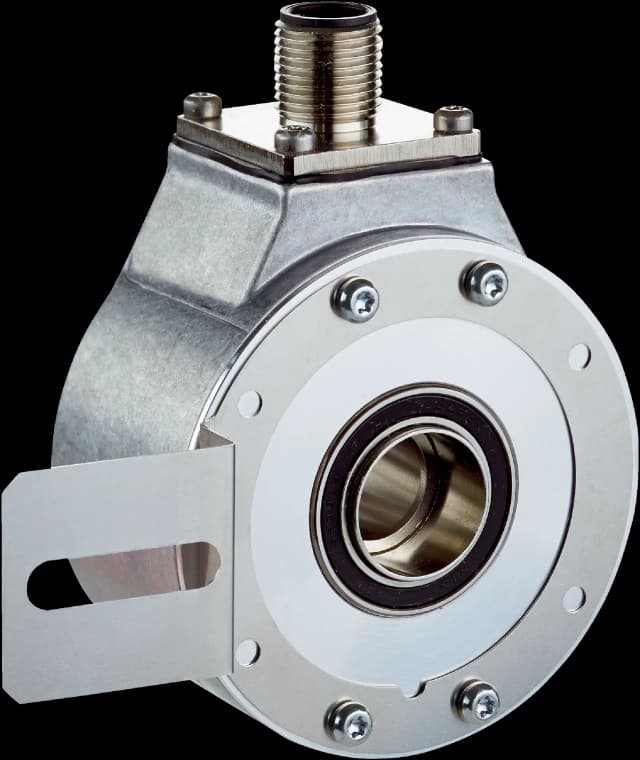
DBS60E-RJFCD1024
Incremental encoders | DBS60 | DBS60E-RJFCD1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Male connector, M12, 8-pin, radial | Pulses per revolution: 1,024 | Flange type / stator coupling: 1-sided stator coupling, slot, screw hole circle radius 31.5–48.5 mm
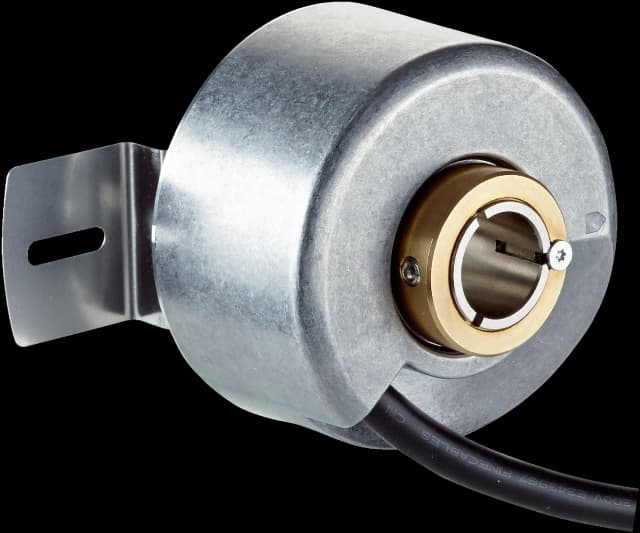
DBS60E-RJFK01000
Incremental encoders | DBS60 | DBS60E-RJFK01000 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 1,000 | Flange type / stator coupling: 2-sided stator coupling, slot, screw hole circle 63–83 mm
DBS60E-RJFK01024
Incremental encoders | DBS60 | DBS60E-RJFK01024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 1,024 | Flange type / stator coupling: 2-sided stator coupling, slot, screw hole circle 63–83 mm
DBS60E-RJFK02000
Incremental encoders | DBS60 | DBS60E-RJFK02000 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 2,000 | Flange type / stator coupling: 2-sided stator coupling, slot, screw hole circle 63–83 mm
DBS60E-RJFK02048
Incremental encoders | DBS60 | DBS60E-RJFK02048 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 2,048 | Flange type / stator coupling: 2-sided stator coupling, slot, screw hole circle 63–83 mm
DBS60E-RJFK04096
Incremental encoders | DBS60 | DBS60E-RJFK04096 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 4,096 | Flange type / stator coupling: 2-sided stator coupling, slot, screw hole circle 63–83 mm
DBS60E-RJFK05000
Incremental encoders | DBS60 | DBS60E-RJFK05000 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 5,000 | Flange type / stator coupling: 2-sided stator coupling, slot, screw hole circle 63–83 mm
DBS60E-RJFKC1024
Incremental encoders | DBS60 | DBS60E-RJFKC1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 1,024 | Flange type / stator coupling: Axial and radial register pin mounting, for 4 mm register pin
DBS60E-RJFKC2048
Incremental encoders | DBS60 | DBS60E-RJFKC2048 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 2,048 | Flange type / stator coupling: Axial and radial register pin mounting, for 4 mm register pin
DBS60E-RJFKD1024
Incremental encoders | DBS60 | DBS60E-RJFKD1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 1,024 | Flange type / stator coupling: 1-sided stator coupling, slot, screw hole circle radius 31.5–48.5 mm
DBS60E-RJFKD2048
Incremental encoders | DBS60 | DBS60E-RJFKD2048 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, universal, 1.5 m | Pulses per revolution: 2,048 | Flange type / stator coupling: 1-sided stator coupling, slot, screw hole circle radius 31.5–48.5 mm
DBS60E-RJFP00100
Incremental encoders | DBS60 | DBS60E-RJFP00100 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, with male connector, M12, 8-pin, universal, 0.5 m | Pulses per revolution: 100 | Flange type / stator coupling: 2-sided stator coupling, slot, screw hole circle 63–83 mm
DBS60E-RJFPC1024
Incremental encoders | DBS60 | DBS60E-RJFPC1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, with male connector, M12, 8-pin, universal, 0.5 m | Pulses per revolution: 1,024 | Flange type / stator coupling: Axial and radial register pin mounting, for 4 mm register pin
DBS60E-RJFPD1024
Incremental encoders | DBS60 | DBS60E-RJFPD1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, with male connector, M12, 8-pin, universal, 0.5 m | Pulses per revolution: 1,024 | Flange type / stator coupling: 1-sided stator coupling, slot, screw hole circle radius 31.5–48.5 mm
DBS60E-RJFQ00100
Incremental encoders | DBS60 | DBS60E-RJFQ00100 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, with male connector, M23, 12-pin, universal, 0.5 m | Pulses per revolution: 100 | Flange type / stator coupling: 2-sided stator coupling, slot, screw hole circle 63–83 mm
DBS60E-RJFQC1024
Incremental encoders | DBS60 | DBS60E-RJFQC1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, with male connector, M23, 12-pin, universal, 0.5 m | Pulses per revolution: 1,024 | Flange type / stator coupling: Axial and radial register pin mounting, for 4 mm register pin
DBS60E-RJFQD1024
Incremental encoders | DBS60 | DBS60E-RJFQD1024 | Mechanical design: Through hollow shaft 5/8″ (rear clamping) | Communication interface: 4.5 V ... 30 V, TTL, HTL, HTL | Connection type: Cable, 8-wire, with male connector, M23, 12-pin, universal, 0.5 m | Pulses per revolution: 1,024 | Flange type / stator coupling: 1-sided stator coupling, slot, screw hole circle radius 31.5–48.5 mm